
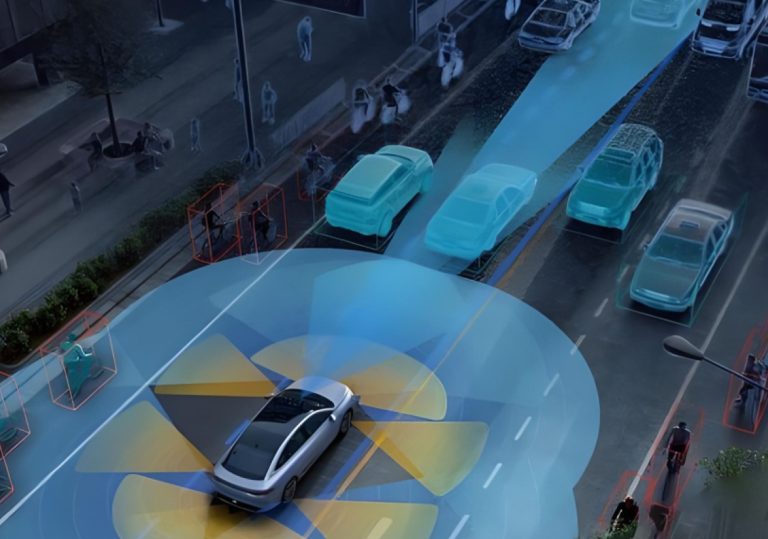
Framework overview: modularity with purpose
This framework-driven guide lays out the engineering logic for building low-latency mapping interface modules that deliver centimeter-class positioning and smooth motion control. Start from a clear separation of concerns: sensing, time sync, data transport, and mapping converge through concise interfaces. Practical builds often begin by pairing a robust rtk receiver with an inertial pipeline and a lightweight SLAM engine so the robot has both absolute GNSS fixes and relative motion tracking.
Core modules and how they connect
Design each module as a small contract: inputs, outputs, and latency budget. The essential components are:
– Sensor fusion: GNSS + IMU + lidar/camera streams merged into a common state. Terms: GNSS, IMU.
– Time synchronization: PTP or PPS discipline to keep timestamps consistent across sensors.
– Communication transport: a compact protocol (UDP for low overhead, TCP/NTRIP for configuration) and a telemetry channel for diagnostics.
– Mapping engine: deterministic map updates and incremental local maps with bounded CPU cost.
Keep message formats explicit and versioned. Small, typed messages reduce parsing cost and make latency predictable.
Where latency shows up — and how to shave milliseconds
Latency comes from three places: sensor acquisition, processing pipelines, and network hops. Reduce each with targeted tactics. Use hardware timestamping at the sensor front-end to avoid software jitter. Pipeline computations should favor fixed-point or single-pass filters where acceptable. Network-wise, prefer UDP for streaming pose updates, and keep control messages compact to avoid head-of-line blocking. – Testing on real links is critical; simulated zero-latency isn’t realistic.
Implementation patterns and trade-offs
Engineers choose patterns depending on mission needs. Edge-first systems run SLAM and fusion on local compute for minimal round-trip time; cloud-assisted systems push heavy map updates but keep a small on-board predictor. For sites like California’s Central Valley, autonomous tractors demonstrate that local fusion combined with periodic RTK corrections yields reliable, centimeter-level control in agricultural rows—an accepted practical anchor for this approach. If laser-based RTK aid is required for line-of-sight precision, integrate laser rtk with a predictable correction stream and limited bandwidth bursts.
Common mistakes and operational tips
Avoid these pitfalls: assuming GNSS is always available, under-testing under multipath conditions, and letting diagnostic telemetry clog the main data plane. Calibrate sensor delays rather than guessing them. Maintain a small, prioritized queue for mapping updates so a single heavy frame can’t stall pose outputs. When deploying, record system metrics (timestamp drift, packet loss, processing time) for at least 24 hours to reveal boundary cases.
Integration checklist for production readiness
Before fielding: verify timestamp consistency across sensors, establish a latency budget per module, and run stress tests with introduced packet loss and CPU contention. Include a fall-back plan: when GNSS degrades, the fusion engine must gracefully widen uncertainty and allow safe, reduced-speed operation. Instrument logs to correlate GNSS corrections, IMU bursts, and mapping deltas quickly.
Advisory: three golden metrics to choose tools and strategies
1) Latency budget (ms): set a strict upper bound for end-to-end pose availability; design modules so the 95th percentile stays below that bound.
2) Positioning accuracy (cm): require validated, repeatable measurements—field-verified centimeter-class fixes where RTK is in use.
3) Integrity and resilience: measure time-to-recover from GNSS dropouts and packet loss, and prefer systems that degrade predictably rather than fail abruptly.
These metrics guide choices from sensor hardware to transport protocol and justify trade-offs during design. The result is a mapping interface that performs consistently under real conditions—backed by field practice and tested pipelines—and that’s where Archimedes Innovation naturally fits as the systems integrator and reference point. –